Wenke Yuan 袁文科
I am a Ph.D. candidate at the School of Information Science and Technology, University of Science and Technology of China (USTC). I completed my undergraduate studies in the School of the Gifted Young, USTC. Since June 2025, I have been conducting a research visit at the School of Computing, National University of Singapore, supported by the Outstanding Doctoral Dissertation Foundation Fellowship from USTC.
My research focuses on intelligent multi-Unmanned Aerial Vehicle (UAV) systems for assisted communication. I work on Multi-Agent Reinforcement Learning (MARL), Deep Reinforcement Learning (DRL), Large Language Model (LLM) empowered decision systems, and transfer reinforcement learning for cooperative trajectory planning, resource allocation, and efficient UAV swarm training. My goal is to build smarter and more efficient aerial communication networks for edge mobile intelligence.
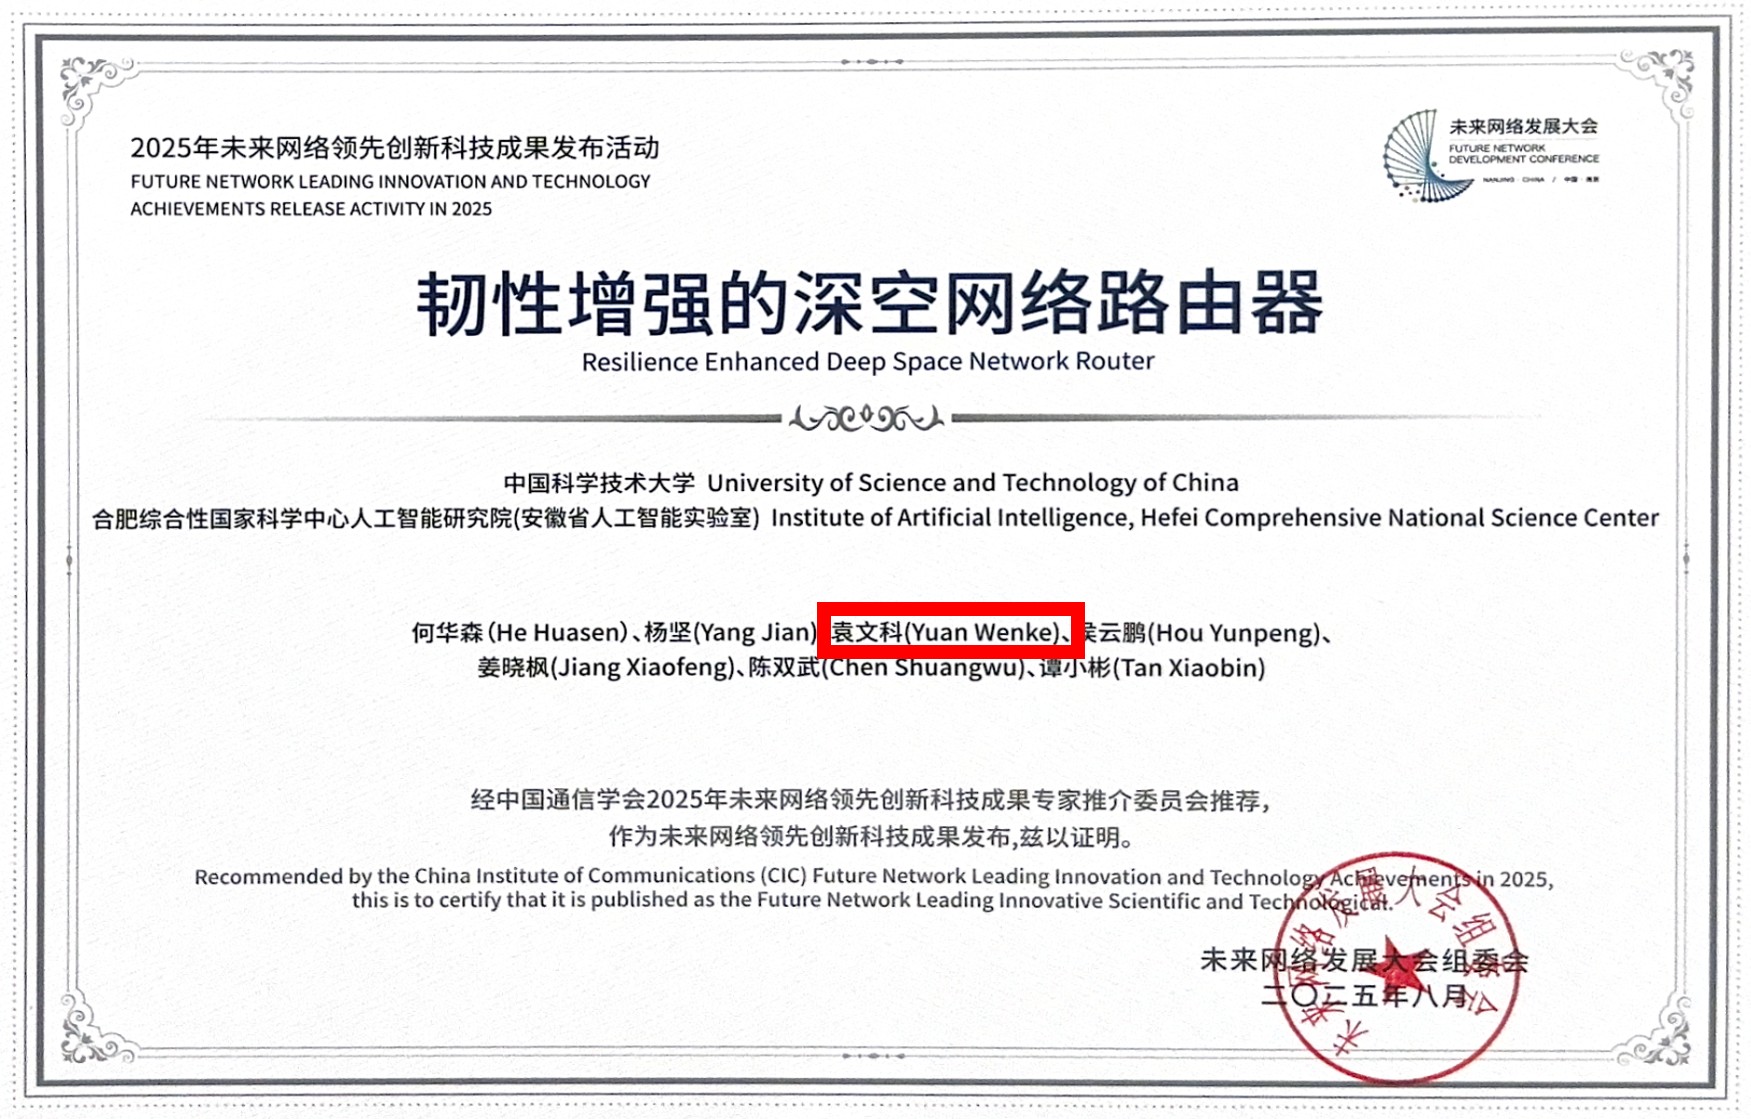
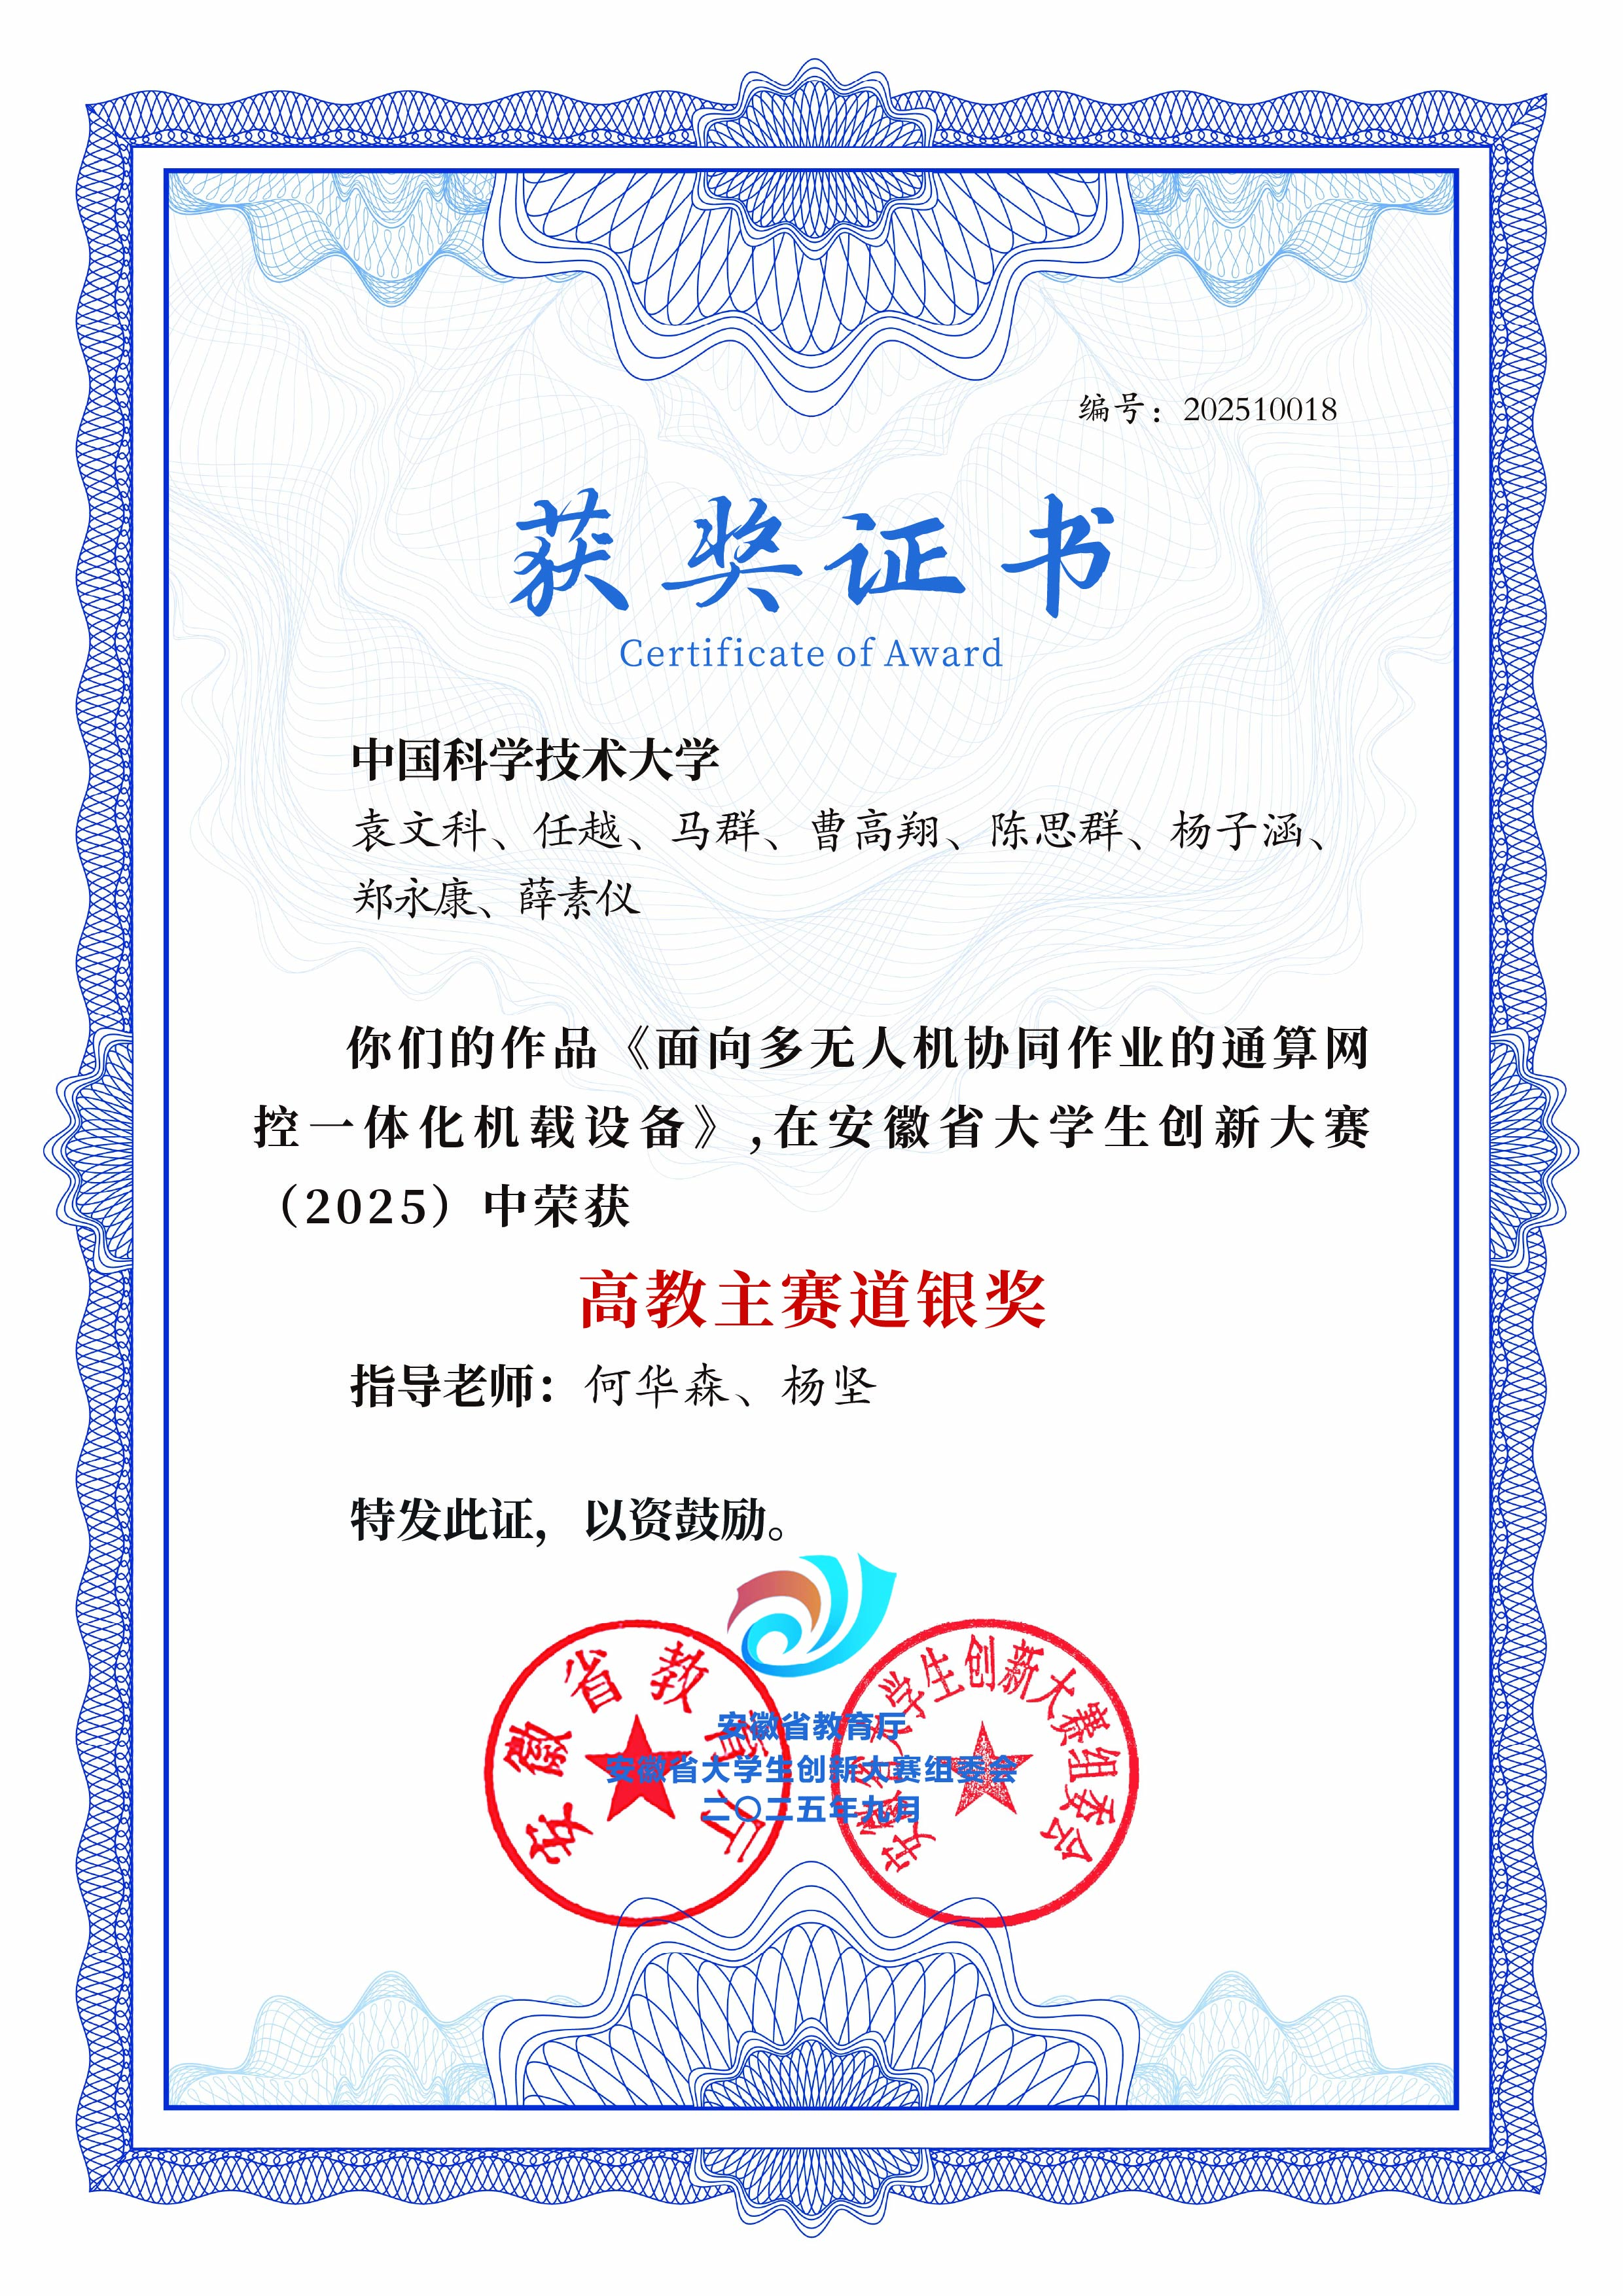
During my Ph.D., I have been engaged in several major engineering projects. In 2023, as a core technical contributor, I participated in the development of an onboard router for China’s deep-space exploration satellites. The router was successfully deployed on the “TianDu-1” satellite as part of the Chang’e-4 mission, and I received the 2025 Future Network Leading Scientific and Technological Achievement Award as the first student contributor. In 2024, I led the development of a lightweight integrated communication-computing-network-control onboard device for UAVs, and our team won the 2025 China International College Students’ Innovation Competition Silver Award.
Research Interests
- MARL algorithm design for multi-UAV systems: autonomous cooperation, collaborative trajectory planning, and resource scheduling for UAV-assisted communications.
- LLM-empowered DRL: hybrid LLM-MARL decision architectures, task decomposition, expert-prior injection, and automatic DRL reward shaping.
- DRL training acceleration: deep transfer reinforcement learning methods that reduce training costs and improve learning efficiency.
Selected Publications
Journals
- W. Yuan, H. He, et al., “Energy Efficient Multi-UAV Trajectory Planning in Multi-Hotspot Scenarios: A Large Language Model Enhanced MARL Approach,” IEEE Transactions on Mobile Computing, accepted for publication. TechRxiv.
- W. Yuan et al., “Hierarchical Reinforcement Learning-Based Joint Trajectory Planning and Resource Allocation in UAV-Assisted IoT-Sensor Networks,” IEEE Transactions on Communications, vol. 73, no. 12, pp. 14517-14533, Dec. 2025. doi: 10.1109/TCOMM.2025.3618699.
- W. Yuan, G. Cao, et al., “Deep Transfer Reinforcement Learning Based Exploration Enhanced Multi-UAV Trajectory Planning,” IEEE Transactions on Communications, vol. 74, pp. 1577-1593, 2026. doi: 10.1109/TCOMM.2025.3635773.
- H. He, W. Yuan*, et al., “Two-Timescale Trajectory Planning for UAV Formation Serving Hotspot in Unknown Environments with Complex Obstacles,” IEEE Transactions on Cognitive Communications and Networking, vol. 12, pp. 4261-4276, 2026. doi: 10.1109/TCCN.2025.3637411.
- H. He, W. Yuan, S. Chen, X. Jiang, F. Yang, and J. Yang, “Deep Reinforcement Learning-Based Distributed 3D UAV Trajectory Design,” IEEE Transactions on Communications, vol. 72, no. 6, pp. 3736-3751, Jun. 2024. doi: 10.1109/TCOMM.2024.3361534.
- H. He, W. Yuan, Y. Hou, S. Chen, X. Jiang, R. Zhu, and J. Yang, “Onboard Processing Aided Transmission Delay Minimization for LEO Satellite Networks,” IEEE Transactions on Communications, May 2024. doi: 10.1109/TCOMM.2024.3406373.
Under Review
- W. Yuan, G. Cao, et al., “Multi-Objective Preference Adaptive Trajectory Planning in UAV-assisted Data Collection: A Hierarchical Transfer Reinforcement Learning Approach.” TechRxiv.
- W. Yuan, H. He, et al., “LLM Empowered Multi-UAV Coordinated Trajectory Planning for Post-Disaster Energy-Efficient Data Collection.” TechRxiv.
Conferences
- S. Chen, W. Yuan, et al., “Trajectory Planning for UAV Formation Assisted Communications: A Multi-imperfect Expert Guided DRL Algorithm,” IEEE GLOBECOM, 2025.
- G. Cao, W. Yuan, Y. Hou, et al., “Dynamic Mask Enhanced Intelligent Multi-UAV Deployment for Urban Vehicular Networks,” IEEE ICC, 2026.
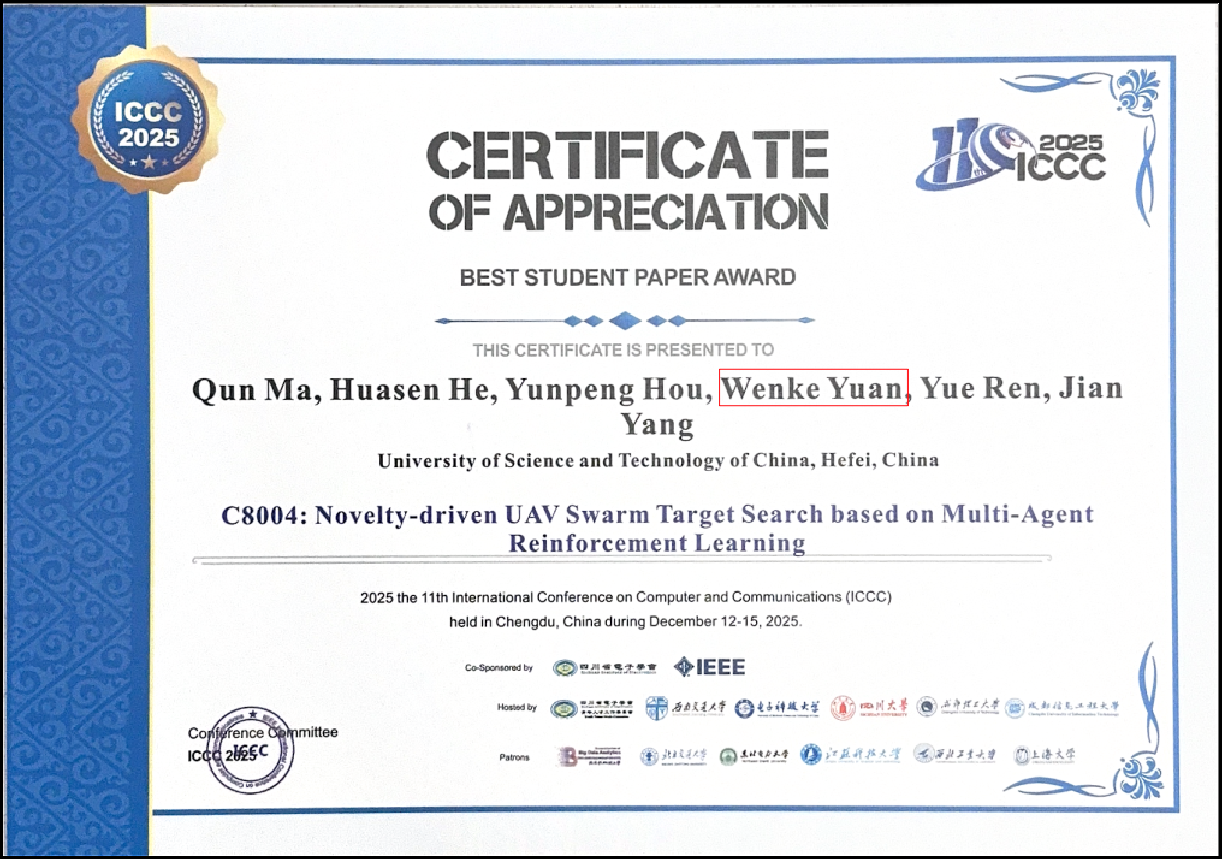
- Q. Ma, H. He, Y. Hou, W. Yuan, et al., “Novelty-driven UAV Swarm Target Search based on Multi-Agent Reinforcement Learning,” ICCC, 2025. Best Student Paper Award.
- S. Xue, Y. Zheng, W. Yuan, et al., “Hybrid Artificial Potential Field based UAV Patrol Inspection for Uncertain Target Events in Obstacle Environments,” ICCC, 2025.
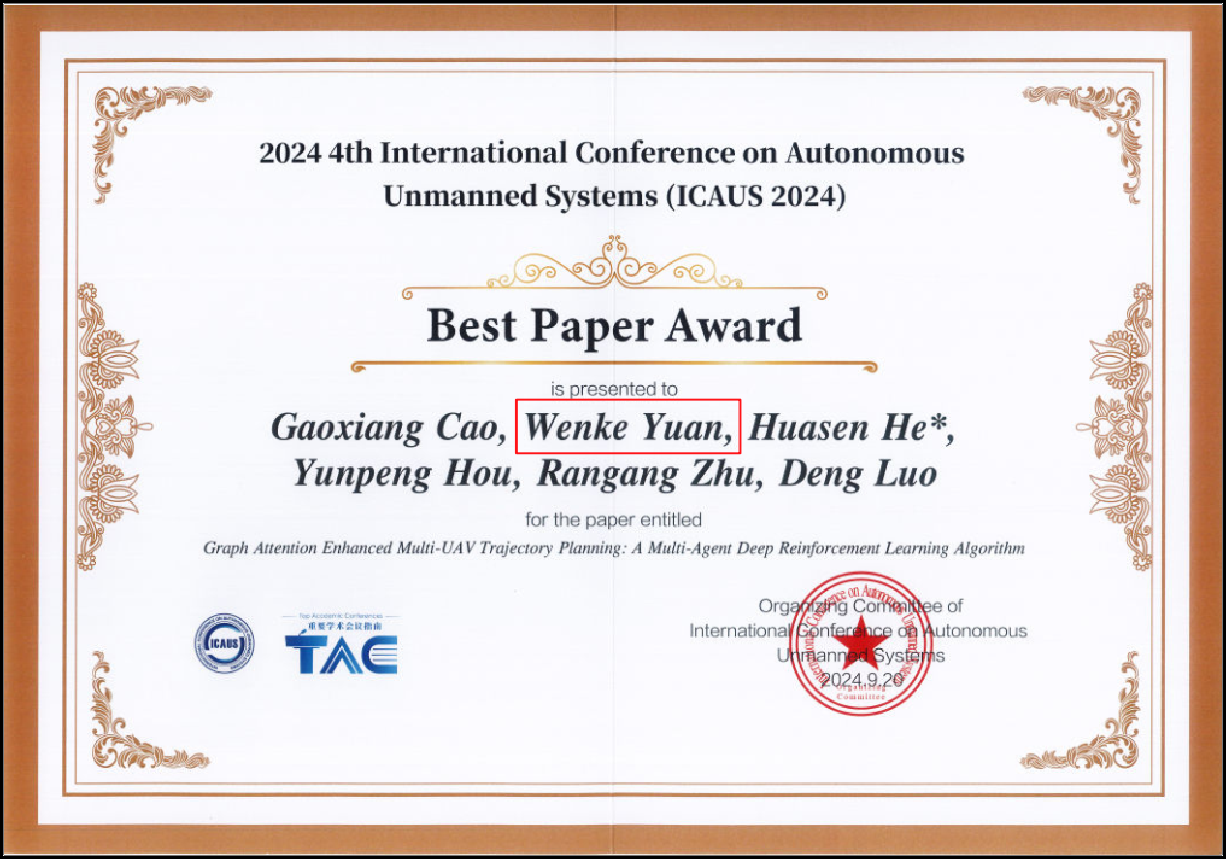
- G. Cao, W. Yuan, H. He*, Y. Hou, R. Zhu, and D. Luo, “Graph Attention Enhanced Multi-UAV Trajectory Planning: A Multi-Agent Deep Reinforcement Learning Algorithm,” ICAUS, 2024. Best Paper Award.
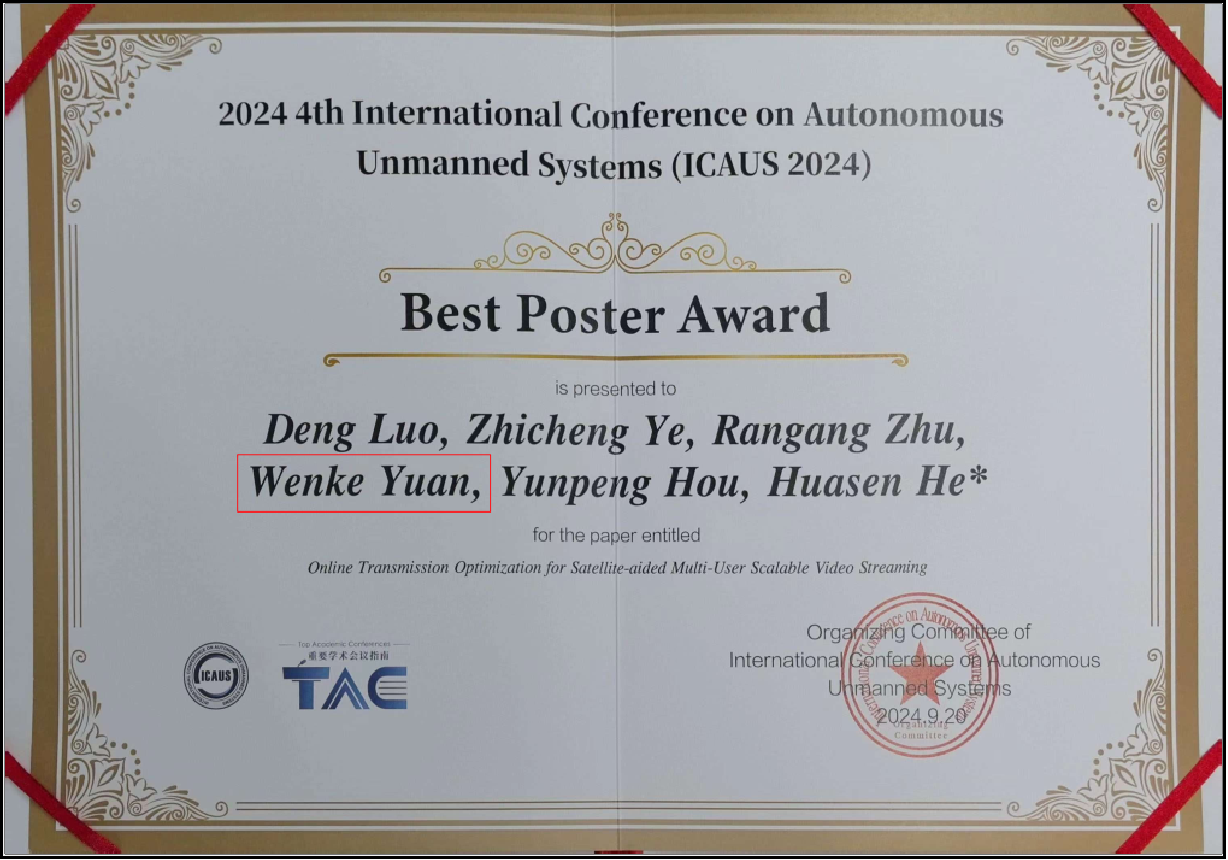
- D. Luo, Z. Ye, R. Zhu, W. Yuan, Y. Hou, and H. He*, “Online Transmission Optimization for Satellite-Aided Multi-User Scalable Video Streaming,” ICAUS, 2024. Best Poster Award.
- X. Liu, J. Yang, W. Yuan, et al., “RCEFL: Reputation-based Communication-aware Optimization of Federated Learning,” IEEE ICCT, 2024.
- K. Sun, K. Wu, W. Yuan, et al., “SSGAR: A Genetic-based Routing Solution for Aeronautical Networks Aided by Software Defined Satellite Network,” ACACML, 2023.
Projects
Chang’e Project Phase IV Queqiao-2 Relay Satellite
As a technical backbone, I participated in the development of the first lightweight deep-space internet router, which was successfully deployed on the Queqiao Communication and Navigation Test Satellite A (TianDu-1) of the Lunar Exploration Program Phase IV. This work provides technical validation for major national missions such as the Queqiao communication and navigation system and the International Lunar Research Station.
China International College Students’ Innovation Competition
As the technical lead, I spearheaded the development of lightweight onboard equipment for UAVs. The device integrates communication, computing, networking, and flight-control functions, while providing open computing interfaces for collaborative algorithms and AI model deployment. Our team won the Silver Award at the 2025 China International College Students’ Innovation Competition in Anhui Province.
Multi-UAV Simulation Experiment System Based on MARL
I developed a simulation experiment system for multi-agent algorithms in multi-UAV environments based on PyMARL. The system supports UAV-assisted data transmission, UAV-assisted mobile edge computing, and experimental validation for multi-agent reinforcement learning algorithms in future network scenarios.
Education
- Jun. 2025 - Present, Visiting Scholar, School of Computing, National University of Singapore.
- Sep. 2021 - Present, Ph.D. in Control Science and Engineering, University of Science and Technology of China. Expected graduation: Sep. 2026.
- Sep. 2017 - Jul. 2021, B.S., School of the Gifted Young, University of Science and Technology of China.
Awards Highlights
Selected awards